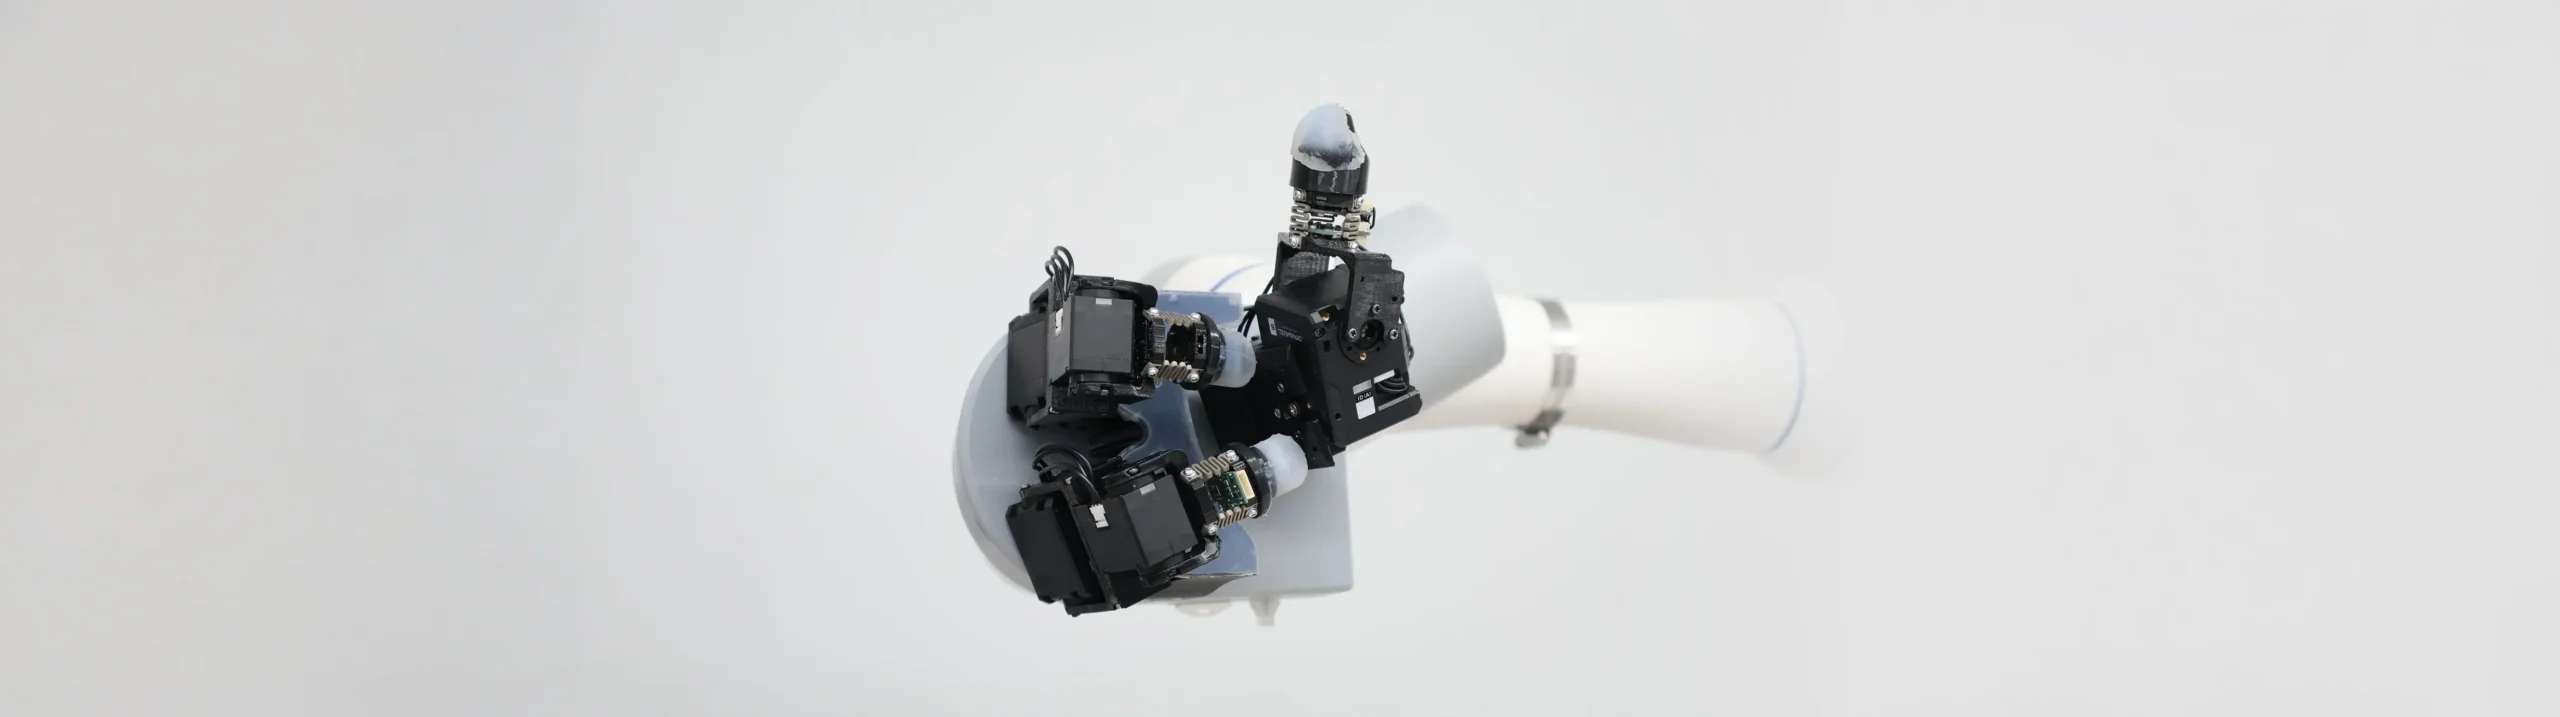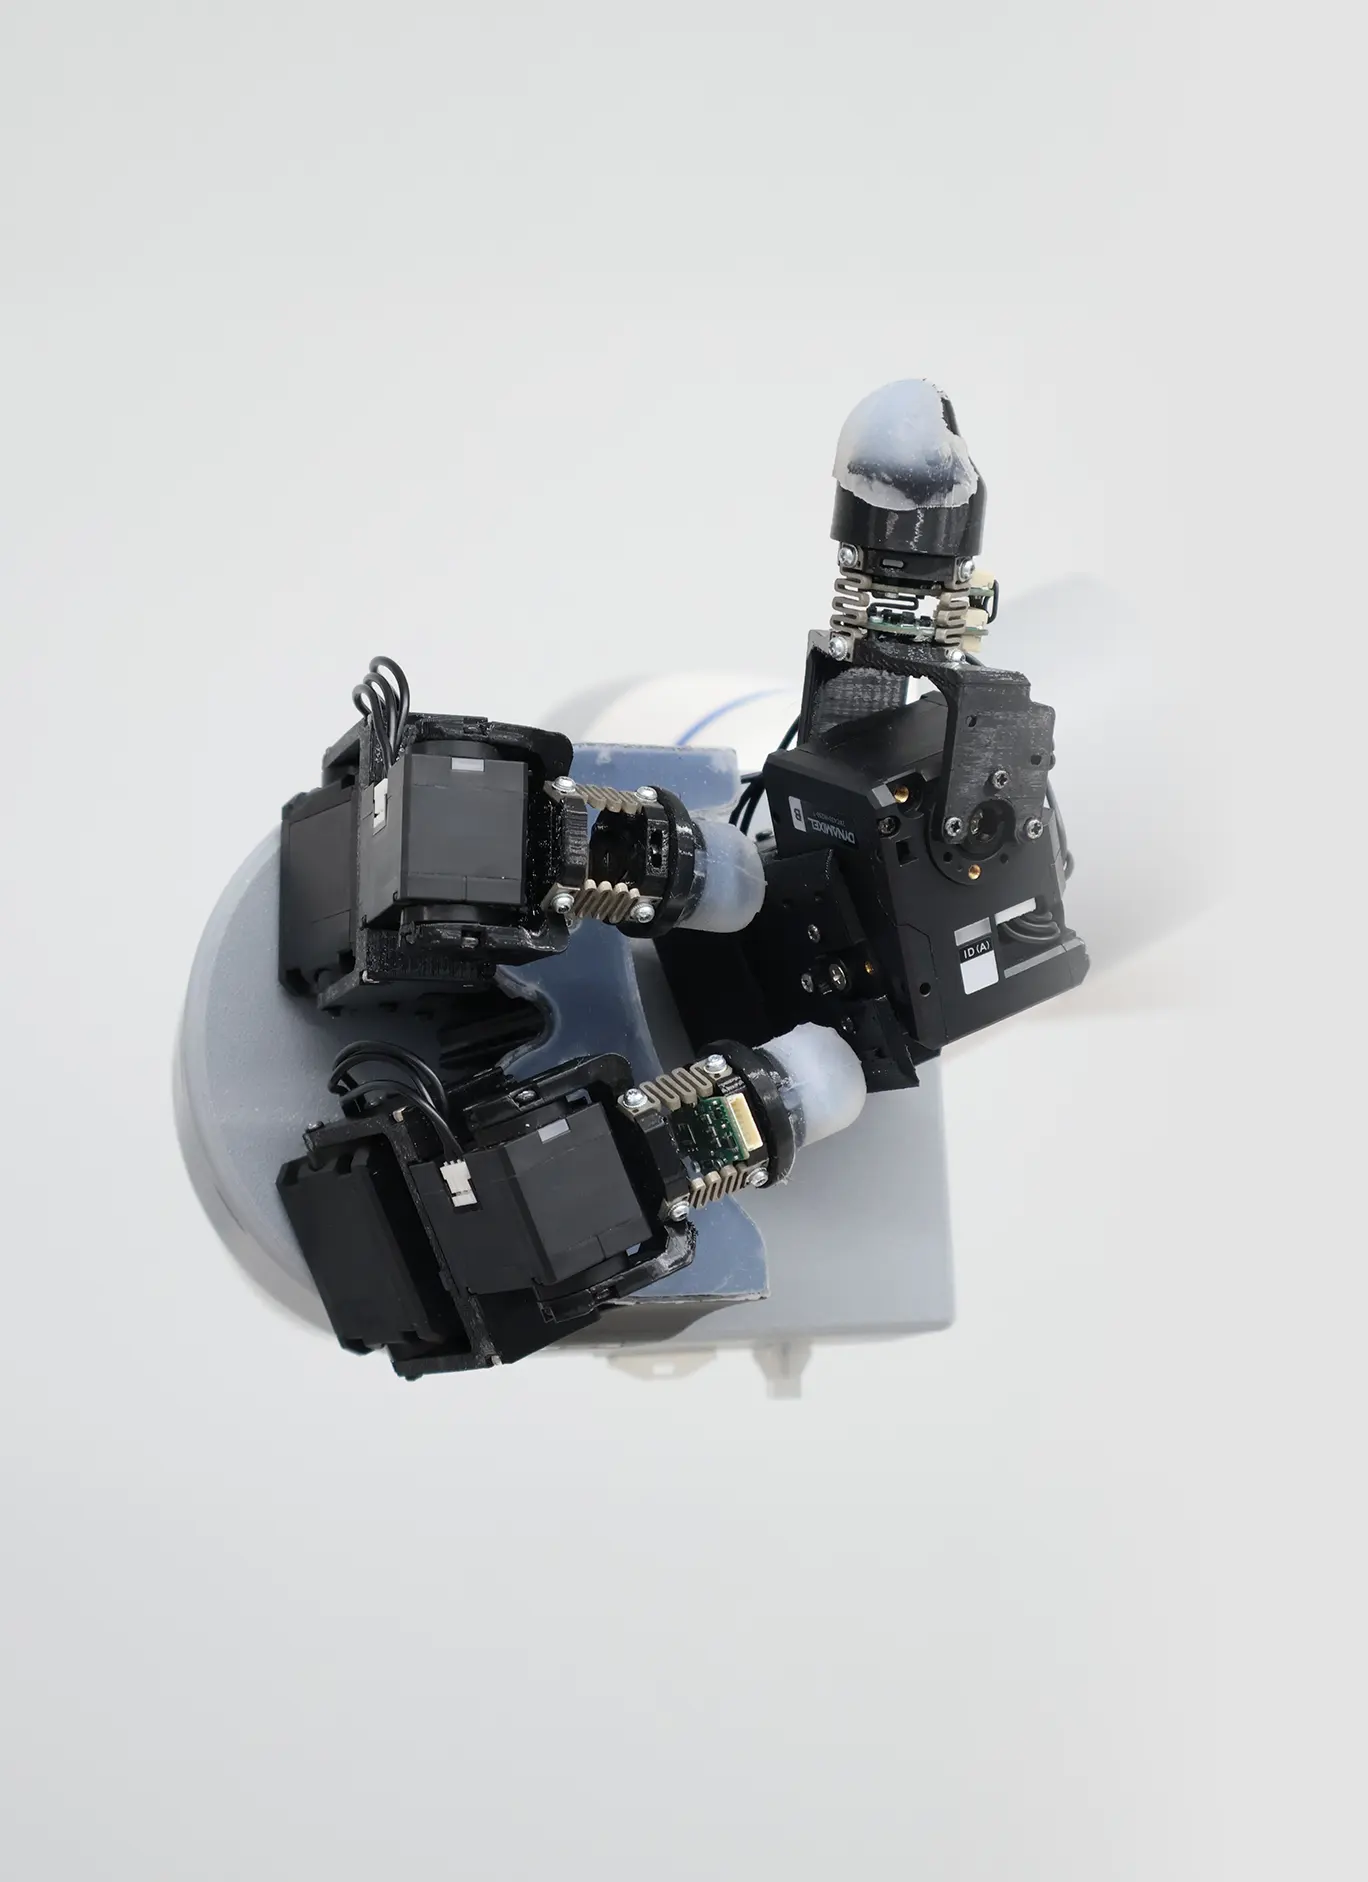
Human grade dexterity for robot hands
Fine motor skill is unlocks the ability to perform critical tasks for what we want our economy to build locally, fast and at scale: unstructured part sequencing and processing, exacting assemblies and manufacturing, installation and maintenance including disassembly, inspection, reassembly and wiring of electrical or mechanical equipment, and many others
Hands-on experience building robots with the upper hand
Spun out of Columbia Engineering’s Robotic Manipulation and Mobility Lab, our founders have advanced the state of the art in robotic touch sensing, designed hands for NASA’s Assistive Free Flyer robots, and co-authored the original Willow Garage manipulation stack for ROS, the Robot Operating System. At Tangent Robotics, we are building a full-stack robotics team to build the missing layer for manipulation.
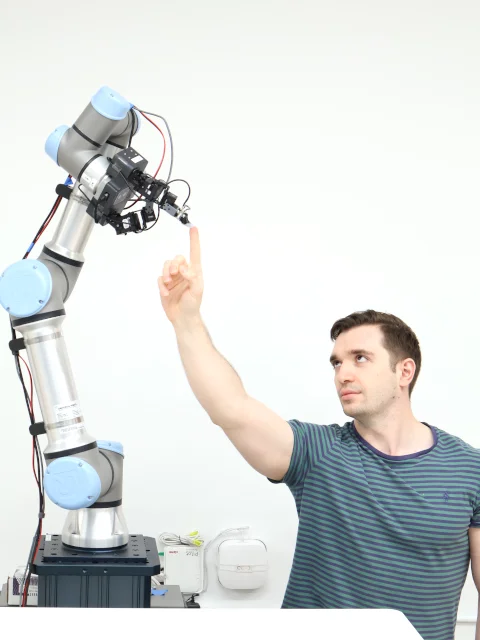
Cem Aygül
Research Scientist, Mechanisms and Design
Federico Ceola
Research Scientist, Robot Learning
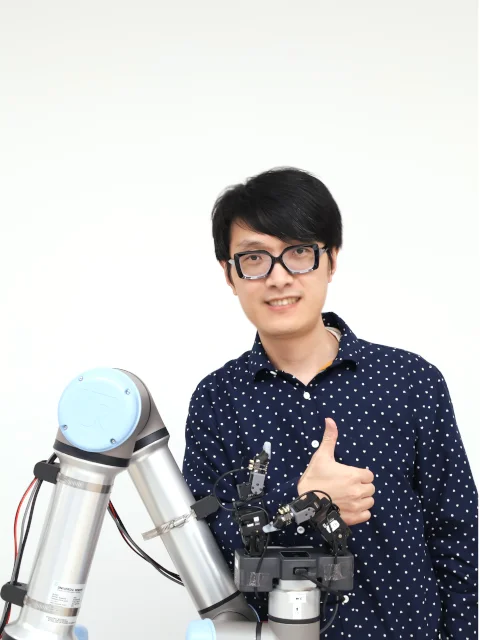
Tianjian Chen
Chief Technology Officer
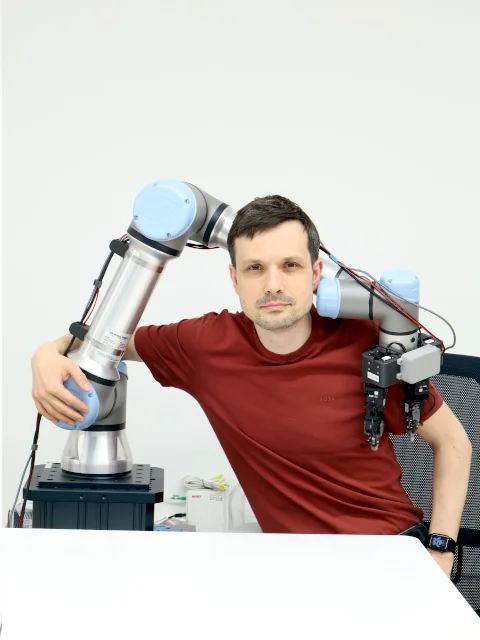
Matei Ciocarlie
Co-Founder, Chief Science Officer
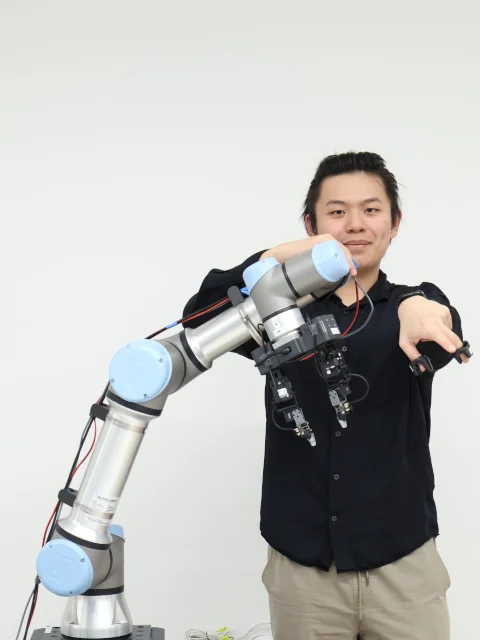
Kai Jiang
Research Engineer, Robot Learning
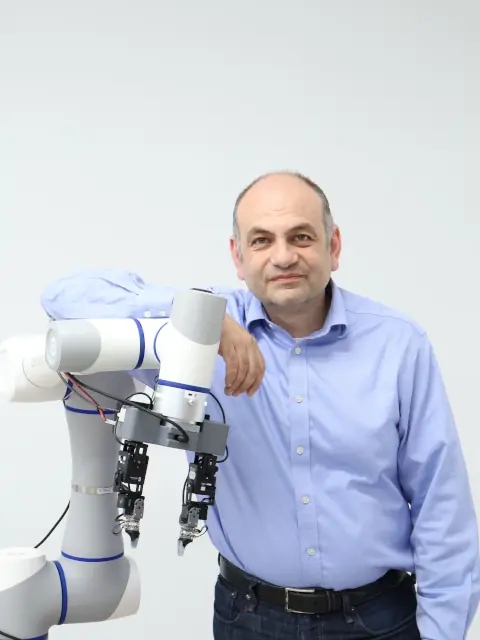
Ioannis Kymissis
Co-Founder, Consultant, Unconventional Electronics
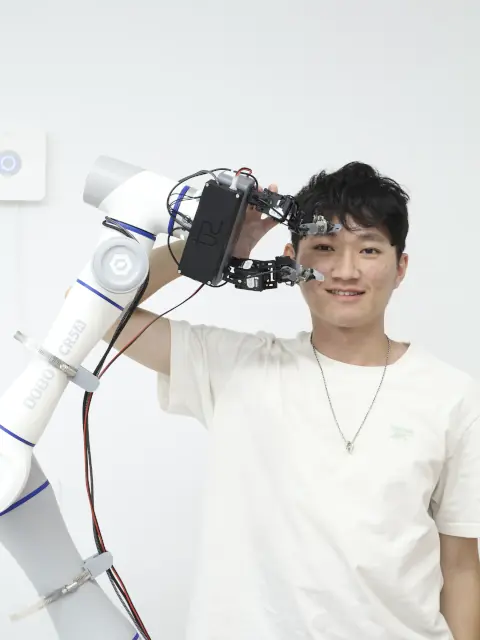
Hua-Hsuan (Wilson) Liang
Software Engineer Intern, Robotic Manipulation
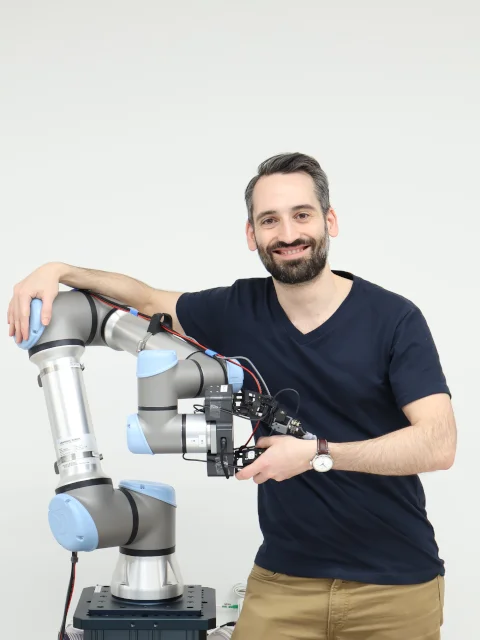
Pedro Piacenza
Co-Founder, Chief Executive Officer
Backed By
Contact Us
We are in the heart of Manhattan, New York City!
Email: info@tangentrobotics.ai